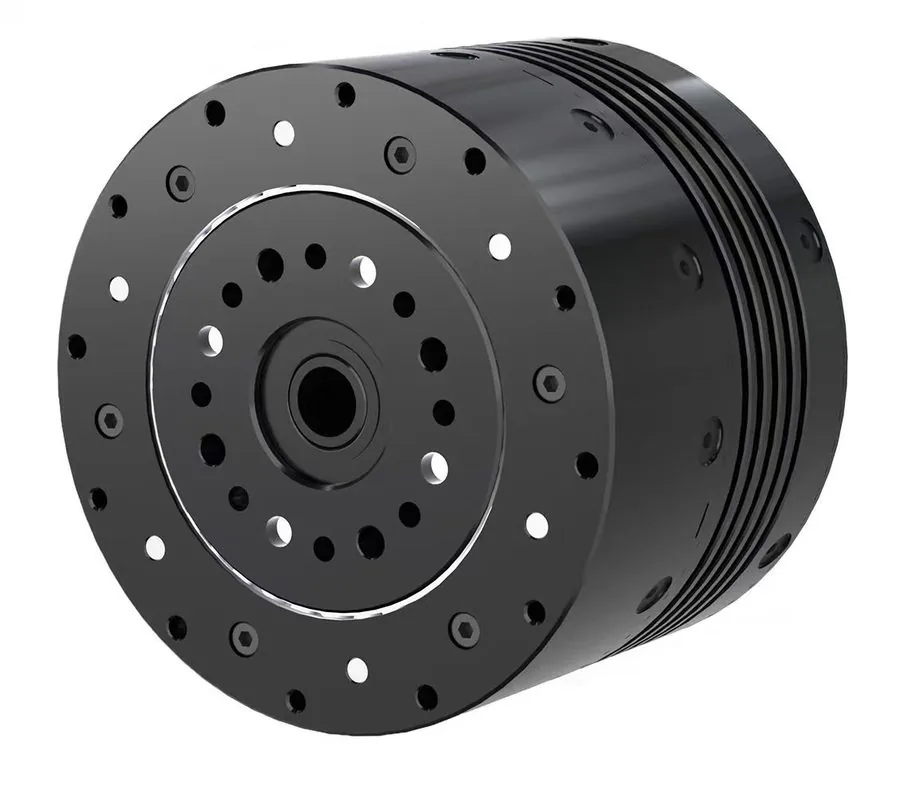
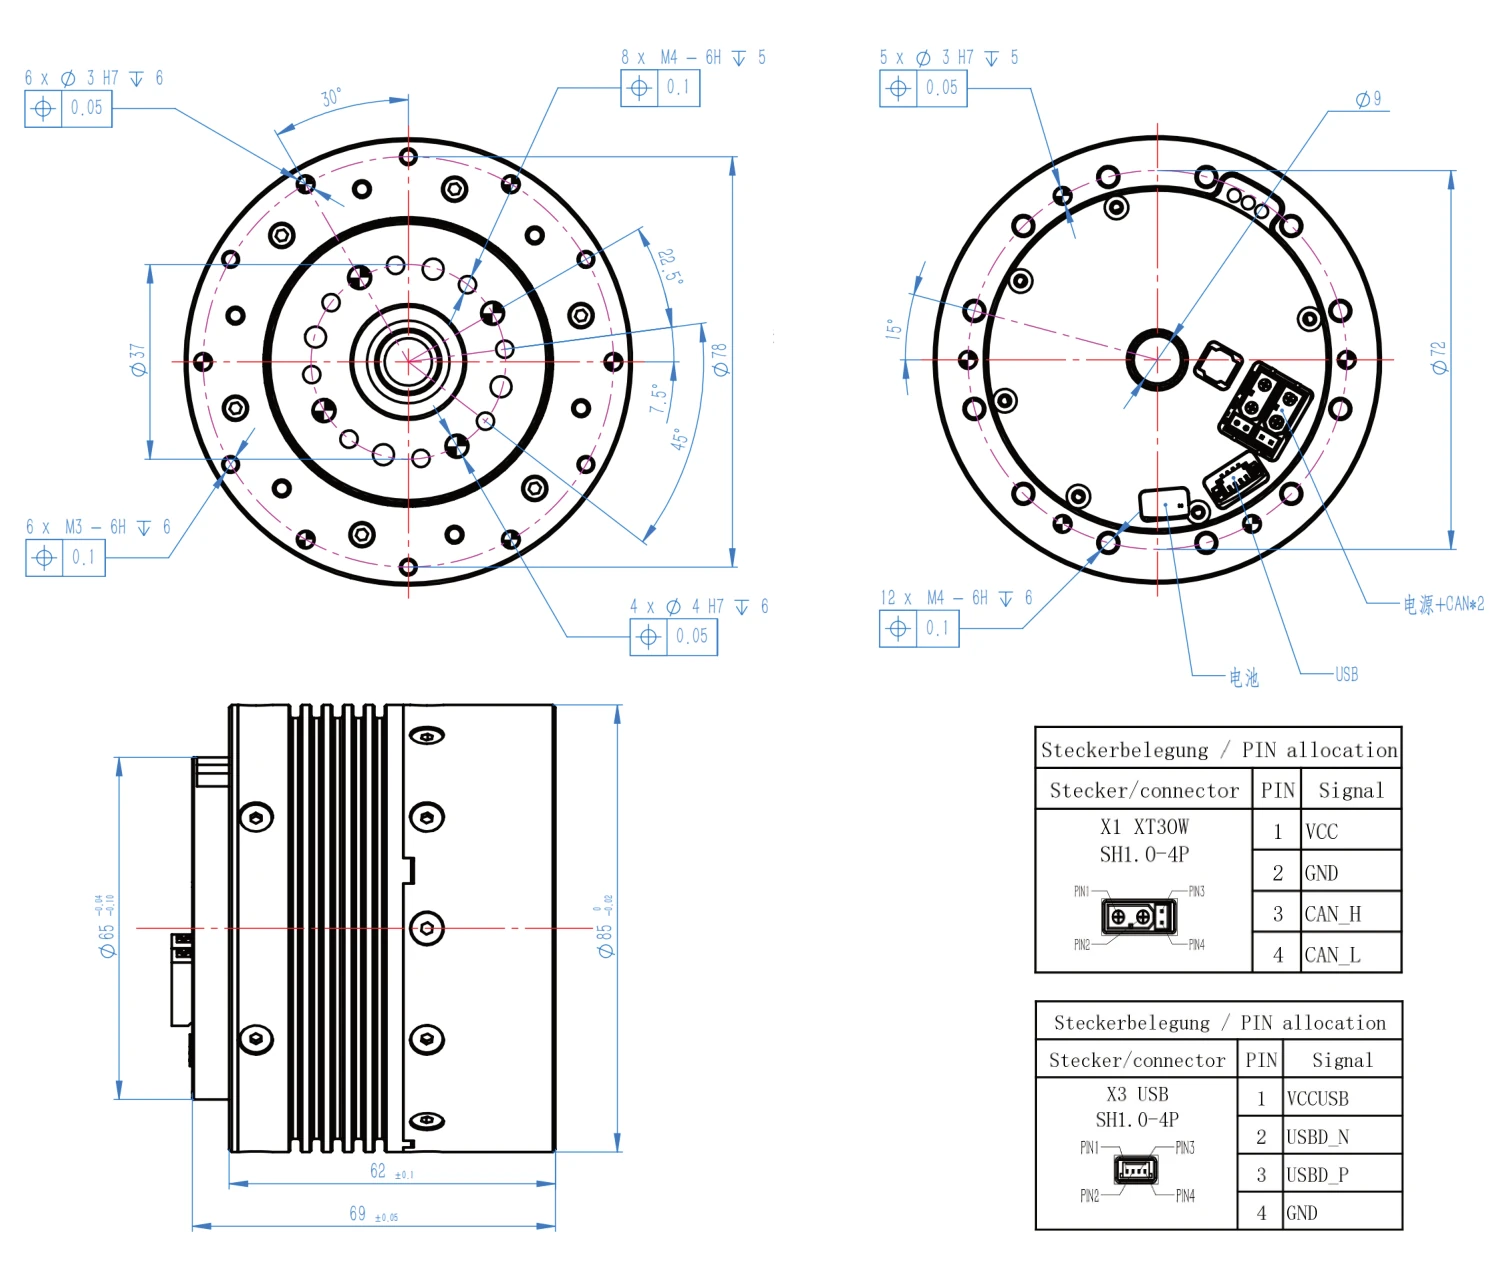
PA76-15-25-ZHK is a Motorevo PA-series integrated planetary joint integrating a brushless motor, planetary reducer, dual encoders and an integrated drive. It delivers 30 Nm rated torque, 90 Nm peak torque and up to 88 rpm, with a total weight of 1000 g. It is designed for humanoid robots, quadruped robots and collaborative arms. It features a hollow through-bore. The standard version does not include a brake. CAN is standard; EtherCAT/CANFD is optional. Alternative KV versions are available on request.
85 mmDiameter
69 mmThickness
30 NmRated Torque
90 NmPeak Torque
88 rpmPeak Speed
1000 gWeight
Electrical Specifications
Operating Voltage
48 V
Rated Voltage
12-72 V
Rated Torque
30 Nm
Rated Speed
50 RPM
Rated Current
8 A(rms)
Peak Torque (>3s)
90 Nm
Peak Speed
88 RPM
Peak Current
25 A(rms)
Torque Constant
3.9 Nm/A
Back EMF Constant
- Vrms/Krpm
Speed Constant
45 rpm/V
Motor Constant
- Nm/√W
Mechanical Time Constant
- ms
Electrical Time Constant
- ms
Pole Pairs
10
Winding Connection
Star (Y)
Phase Resistance
1.26 Ω
Phase Inductance
1.52 mH
Mechanical Specifications
Diameter
85 mm
Thickness
69 mm
Weight
1000 g
Gear Ratio
25
Backlash
10 Arcmin
Output Bearing
Crossed roller bearing
Backdrive Torque
1 Nm
Rotor Inertia
- g·cm²
Axial Load
7.9 kN
Radial Load
3.5 kN
Control & Communication
Control Bandwidth
2000 Hz
Communication
CAN (EtherCAT/CANFD optional)
Encoder Type
Mechanical dual encoder
Encoder Resolution
14 bit
CAN Interface
XT30(2+2)PB-M
USB Interface
SH1.0-4P
Power Interface
XT30(2+2)PB-M
Control Modes
Servo Mode
✓
Velocity Mode
✓
Torque Mode
✓
Hybrid Force-Position Mode
✓
Protection
Overvoltage Protection
✓
Overcurrent Protection
✓
Overtemperature Protection
✓
Environment & Reliability
Duty Cycle
S2 (short-time duty)
Ingress Protection
IP40 (standard; IP54 optional on request)
Cooling Method
IC410 (self-cooled)
Operating Temperature
-20°C to 50°C
Insulation Class
F
Dielectric Strength
500V 1kHz 1A 1ms
Insulation Resistance
100 MΩ @ 20°C
Temperature Sensor
NTC MF52B 103F3950
Noise
60 dB / 0.5 m
Loading 3D teardown…
The 3D teardown is generated from this model’s diameter, thickness, gear ratio and hollow bore. Orbit, explode and inspect 15 components.