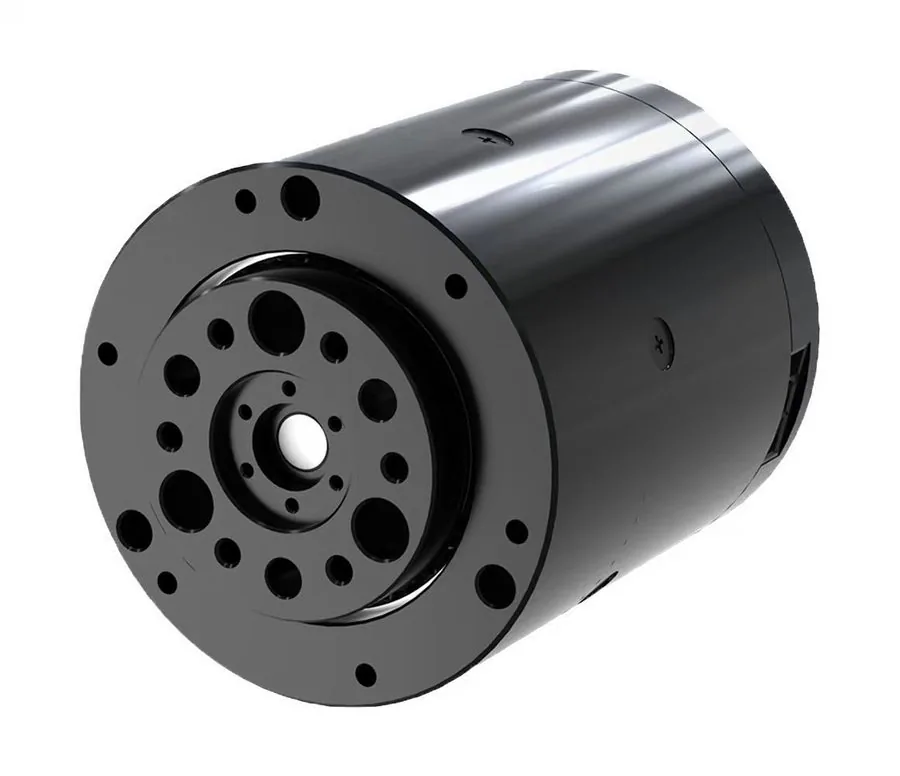
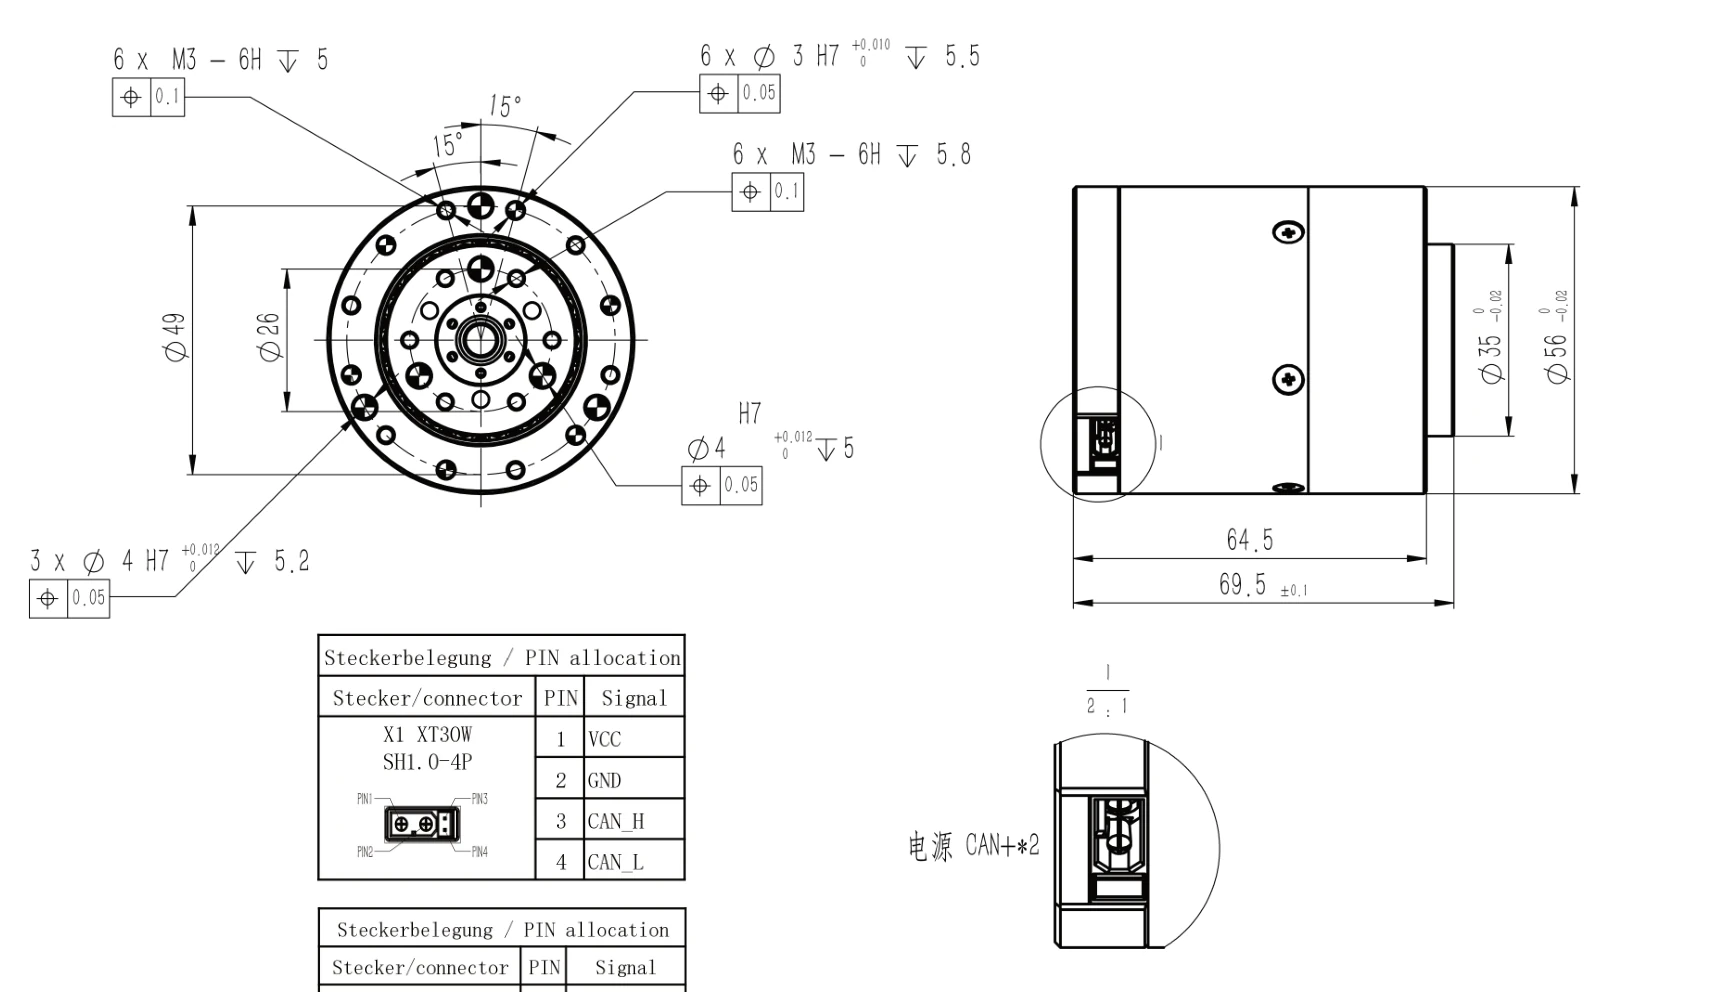
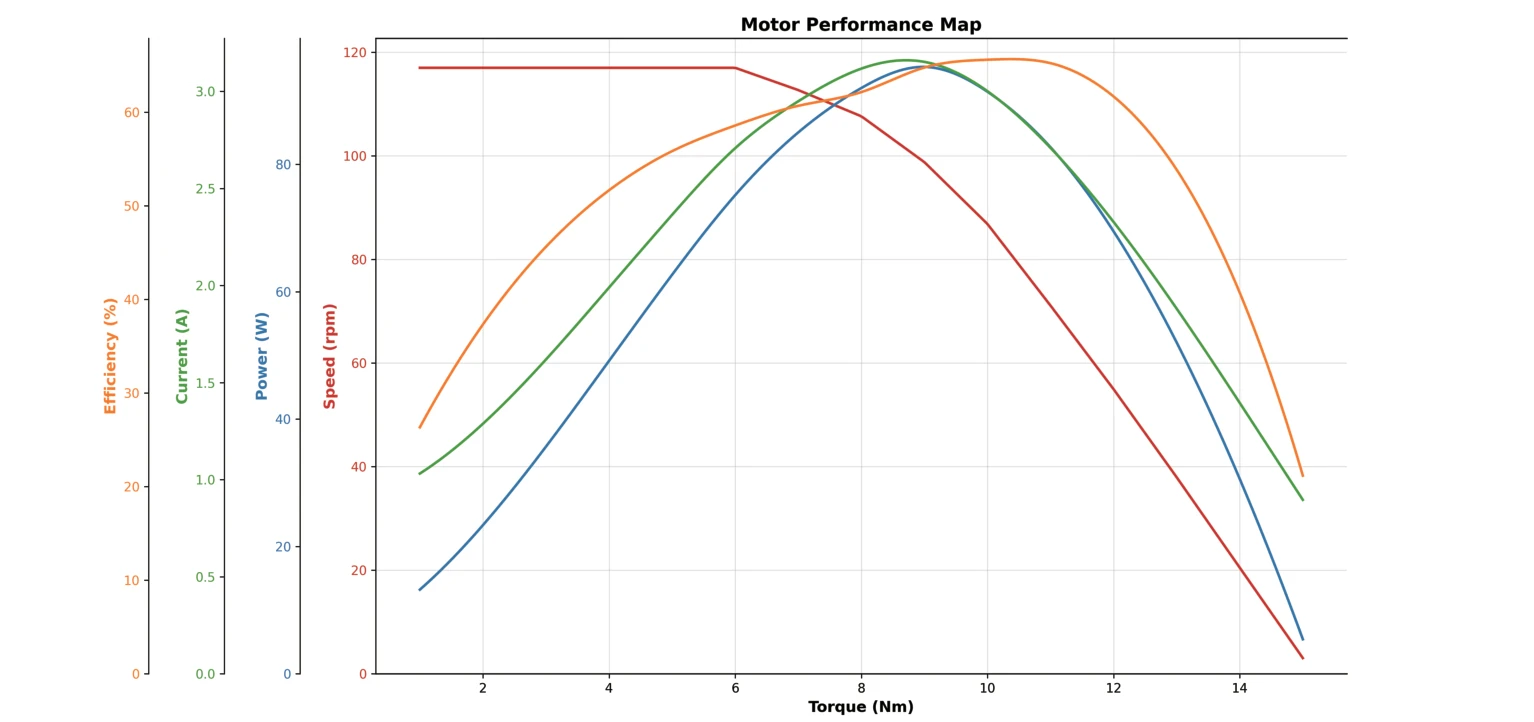
PA43-15-36 is a Motorevo PA-series integrated planetary joint integrating a brushless motor, planetary reducer, dual encoders and an integrated drive. It delivers 20 Nm rated torque, 70 Nm peak torque and up to 117 rpm, with a total weight of 530 g. It is designed for humanoid robots, quadruped robots and collaborative arms. The standard version does not include a brake. CAN is standard; EtherCAT/CANFD is optional. IP54 protection is available on request. An optional steel output plate is available.
56 mmDiameter
69.5 mmThickness
20 NmRated Torque
70 NmPeak Torque
117 rpmPeak Speed
530 gWeight
Electrical Specifications
Operating Voltage
48 V
Rated Voltage
12-60 V
Rated Torque
20 Nm
Rated Speed
80 RPM
Rated Current
7 A(rms)
Peak Torque (>3s)
70 Nm
Peak Speed
117 RPM
Peak Current
25 A(rms)
Torque Constant
2.93 Nm/A
Back EMF Constant
- Vrms/Krpm
Speed Constant
87 rpm/V
Motor Constant
- Nm/√W
Mechanical Time Constant
- ms
Electrical Time Constant
- ms
Pole Pairs
14
Winding Connection
Star (Y)
Phase Resistance
0.9 Ω
Phase Inductance
0.41 mH
Mechanical Specifications
Diameter
56 mm
Thickness
69.5 mm
Weight
530 g
Gear Ratio
36
Backlash
10 Arcmin
Output Bearing
Crossed roller bearing
Backdrive Torque
0.7 Nm
Rotor Inertia
- g·cm²
Axial Load
4.8 kN
Radial Load
2.1 kN
Control & Communication
Control Bandwidth
2000 Hz
Communication
CAN (EtherCAT/CANFD optional)
Encoder Type
Mechanical dual encoder
Encoder Resolution
14 bit
CAN Interface
XT30(2+2)PB-M
USB Interface
SH1.0-4P
Power Interface
XT30(2+2)PB-M
Control Modes
Servo Mode
✓
Velocity Mode
✓
Torque Mode
✓
Hybrid Force-Position Mode
✓
Protection
Overvoltage Protection
✓
Overcurrent Protection
✓
Overtemperature Protection
✓
Environment & Reliability
Duty Cycle
S2 (short-time duty)
Ingress Protection
IP40 (standard; IP54 optional on request)
Cooling Method
IC410 (self-cooled)
Operating Temperature
-20°C to 50°C
Insulation Class
F
Dielectric Strength
500V 1kHz 1A 1ms
Insulation Resistance
100 MΩ @ 20°C
Temperature Sensor
NTC MF52B 103F3950
Noise
60 dB / 0.5 m
Loading 3D teardown…
The 3D teardown is generated from this model’s diameter, thickness, gear ratio and hollow bore. Orbit, explode and inspect 15 components.